

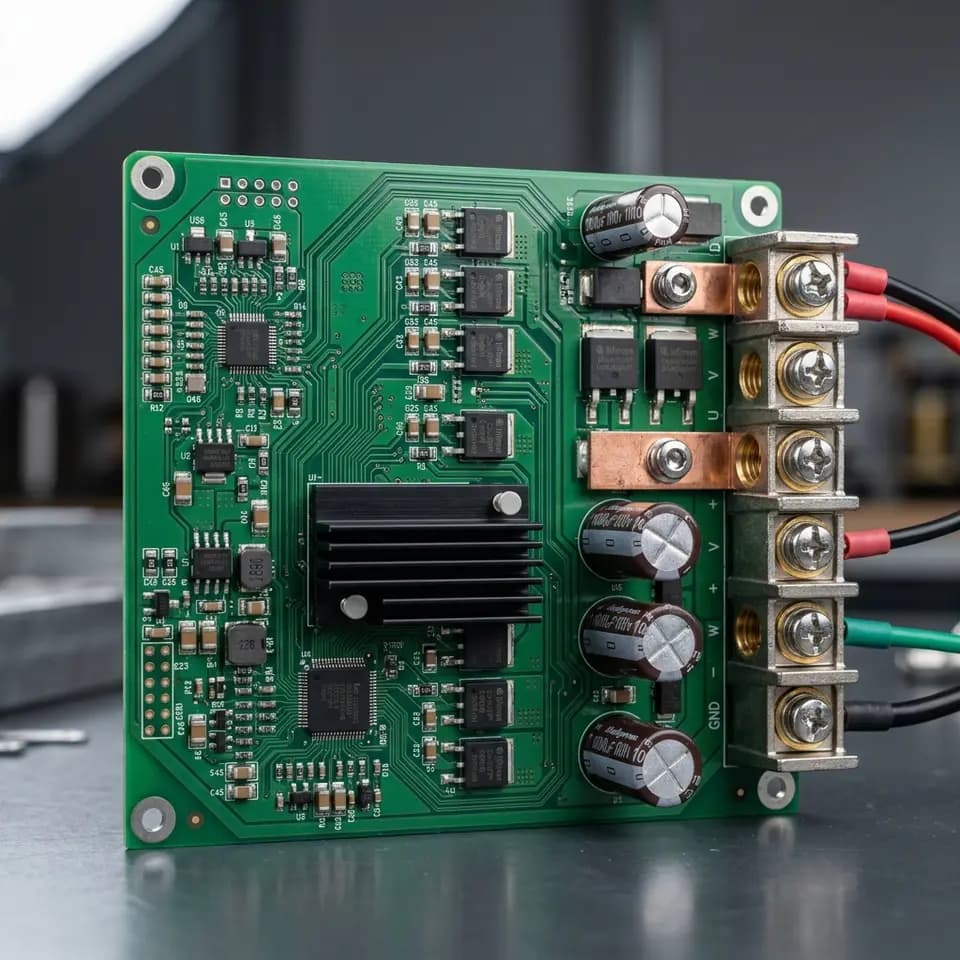
24V GaN BLDC Driver Board
Triage your BLDC drive requirements—from phase current to FOC commutation—and validate OEM readiness before freezing your actuator envelope.
Published 2026-07-24 | Last updated 2026-07-27. Engineering sources reviewed July 27, 2026.
Ready for BLDC constraints
Configure current, commutation, and feedback to generate feasibility insights.
Design Realities for 24V BLDC Drives
Building a compact 24V GaN BLDC driver board requires balancing switching frequency, control topology (FOC vs Trapezoidal), and feedback loops. This report outlines the engineering boundaries.
Decision Conclusion
24V is best when the current envelope stays disciplined
The page target is a compact 24V GaN BLDC driver board, so the useful design window is driven more by phase current and cooling path than by bus voltage alone.
Evidence: The calculator flags 30A+ RMS and 600W+ continuous cases for thermal and copper review.
Decision Conclusion
FOC plus encoder feedback is the preferred precision path
For robotics, gimbals, and medical motion, the strongest fit is FOC with absolute or incremental feedback because it supports smooth torque and repeatable zero-speed behavior.
Evidence: The tool applies penalties to trapezoidal control and no-feedback configurations, then surfaces those limits in result notes.
Decision Conclusion
Sensorless and trapezoidal options remain valid but narrower
They can reduce BOM, firmware, or connector complexity, but they should not be treated as equivalent to closed-loop FOC for holding torque or low-speed precision.
Evidence: The commutation table and risk matrix separate waveform, feedback, and startup behavior instead of presenting one generic BLDC recommendation.
Decision Conclusion
RFQ readiness depends on validation evidence, not a single score
A feasible sizing result should trigger thermal, EMI, current-sense, and connector checks before a board outline is frozen.
Evidence: The validation plan lists the minimum measurements and artifacts required before production design release.
FOC
Optimal Control Path
Field Oriented Control leverages GaN's high switching speeds (50-100kHz) to support smoother torque, high efficiency, and reduced acoustic noise when the current loop and layout are validated.
100kHz
Maximized PWM
GaN reduces switching-loss pressure, making 100kHz-class PWM practical in reference designs. This can reduce audible noise and bulky capacitance when layout and thermal limits are met.
SPI
Preferred Feedback
For precise position control at 24V, absolute encoders (SPI/SSI) offer immediate zero-speed torque without the startup jitter of sensorless designs.
Recommended Use Cases
- Collaborative Robotic Arms:
24V bus matches safety limits while FOC ensures smooth, human-safe motion profiles.
- Precision Gimbal Drives:
High PWM frequency eliminates micro-vibrations, critical for optical stability and tracking.
- Medical Pumps and Centrifuges:
Silent operation and strict thermal limits make GaN BLDC drives ideal for laboratory environments.
Challenging Scenarios
- High-Power Heavy Traction (>1kW):
Driving 1kW+ on a 24V bus creates immense phase currents (40A+ RMS). Upgrade to 48V or 60V to reduce I²R losses.
- High-Ambient Environments (>105°C):
While GaN FETs handle heat well, standard compact FR4 PCBAs and associated passive components degrade rapidly above 105°C ambient.
- Cost-Bottom Consumer Goods:
Simple fans or cheap toys using basic 6-step trapezoidal control rarely justify the premium layout of a custom GaN board.
Commutation Impact on GaN Hardware
| Commutation Type | Current Profile | GaN Advantage | Board Design Impact |
|---|---|---|---|
| Field Oriented Control (FOC) | Smooth sinusoidal currents aligned with motor flux. | 100kHz-class PWM can reduce current ripple when current sensing, dead-time, and layout are tuned. Reduced reverse-recovery effects lower one source of switching stress. | Requires precision current shunts and capable MCU, but can deliver lower motor operating temperatures after thermal validation. |
| Trapezoidal (6-Step) | Block commutation causing current ripples and torque steps. | Reduced switching losses still apply, but the motor fundamentally sees jagged waveforms. | Simpler MCU requirements, but higher motor acoustic noise and higher peak phase stresses. |
| Sensorless BEMF | Relies on back-EMF; poor zero-speed performance. | Cleaner switching transitions can make BEMF sampling easier than noisy layouts, but startup tuning remains the limiting factor. | Saves board space (no encoder connectors), but unsuitable for high-holding-torque robotics. |
What Must Be Proven Before Production
A 24V GaN BLDC driver board can look feasible in a sizing tool and still fail at the connector, enclosure, firmware, or EMI stage. Use these gates to turn the calculator result into RFQ evidence.
| Gate | Decision Question | Evidence Needed | Fail Signal |
|---|---|---|---|
| Electrical envelope | Can the board support the RMS and burst current profile? | Motor phase-current profile, duty cycle, current-sense topology, copper weight, and peak-current duration. | Burst current is close to RMS current, or continuous power exceeds the thermal path available in the enclosure. |
| Thermal path | Where does the heat leave the PCBA? | Metal housing contact, thermal interface material, via field, ambient temperature, airflow, and continuous duty cycle. | A small board is expected to run 30A+ RMS in a sealed plastic pocket without conduction into the product chassis. |
| Control and feedback | Does the commutation mode match the motion requirement? | FOC/trapezoidal/sensorless choice, encoder or Hall interface, zero-speed torque need, startup load, and firmware ownership. | Sensorless control is requested for a robotic joint that must hold position at zero speed or recover from abrupt load steps. |
| Production readiness | Can the layout survive manufacturing and compliance review? | Connector current rating, creepage/clearance, EMI test plan, programming fixture, calibration process, and end-of-line test coverage. | The power stage is sized, but there is no defined fixture, firmware flashing path, or EMI mitigation plan. |
Good first RFQ fit
15A RMS, 30A burst, FOC, absolute encoder, metal housing contact, and a defined board envelope.
Needs architecture review
32A RMS, 80A burst, compact sealed enclosure, and no clear conduction path. The first decision is thermal architecture, not schematic capture.
Control-risk fit
Sensorless operation on a load that starts under torque or must hold position. Add feedback or relax the motion requirement before RFQ.
Visualizing the PWM Frequency Trade-Off
Higher frequency yields smoother torque
Standard silicon BLDC boards often limit PWM to 20kHz to avoid thermal runaway from switching losses, requiring 200ns+ dead-times. This low frequency creates current ripple, which can translate to motor heat and audible whine. GaN can make 50kHz–100kHz PWM practical with lower switching-loss pressure under the right layout and thermal conditions. Reference designs also point to short dead-time operation and reduced reverse-recovery effects, which can support smoother phase current for precision positioning.
Evidence, Assumptions, and Limits
Source review date: July 27, 2026. Claims are for RFQ preparation, not final production specs.
Calculator Assumptions
- Calculates based on a nominal 24V DC bus line.
- FOC commutation is heavily favored for optimizing area and efficiency.
- Board-area estimations include keep-outs for connectors and sensors but must be verified against actual DXF outlines.
Production Validation Gates
- Thermal simulation under continuous duty cycle.
- EMI and switch-node ringing validation at 100kHz PWM.
- Firmware tuning for current-sense loops and dead-time minimization.
| Traceable Source | Context | Supports | Limit |
|---|---|---|---|
| EPC low-voltage BLDC motor-drive application note | Used to frame why 24V GaN boards can be compact, but not to guarantee a finished GanServo current rating. | Documents low-voltage GaN BLDC design considerations including short dead-time ranges and reverse-recovery behavior in 24V-48V motor-drive contexts. | Reference-design conditions only; actual continuous BLDC current ratings vary by enclosure thermal dissipation. |
| TI 24V-60V GaN inverter reference design guide | Used for PWM, layout, and DC-link trade-off discussion before GanServo-specific packaging review. | Shows 24V-60V GaN inverter design guidance, 100kHz-class PWM operation, and ceramic DC-link capacitor strategy. | Reference design scale and power level differ from ultra-compact embedded PCBAs. |
| GaN advantages in high-speed BLDC motors | Used to explain the control and layout rationale behind the tool recommendations. | GaN driver selection, reduced switching losses, and layout discipline for precision torque control with lower acoustic risk. | Training material provides topology guidance, not a certified 24V BLDC actuator limit. |
| GanServo 24V BLDC sizing model | Reviewed July 27, 2026 for this page and exposed through the interactive sizer above. | Maps continuous current, burst current, commutation, and feedback choices to RFQ triage bands for a 24V custom PCBA. | Internal planning model only; it requires motor constants, copper stack-up, and thermal-path review before release. |
| GanServo RFQ intake checklist | Used to keep the final CTA focused on the next decision rather than generic sales copy. | Defines the minimum fields needed to quote: RMS current, burst current, board envelope, motor feedback, cooling path, and operating duty cycle. | Intake checklist is not a compliance report or final manufacturing sign-off. |
Risk Matrix Before RFQ
Encoder Noise Injection
High dv/dt from fast GaN switching can couple into unshielded SPI/SSI encoder lines.
Mitigation: Reserve routing channels, shielding, differential options, ground-plane continuity, and local decoupling before board outline lock.
Dead-Time Firmware
Shorter dead-time can improve efficiency, but it also tightens MCU timing and gate-driver validation.
Mitigation: Treat dead-time as a firmware and oscilloscope validation item, not a copied reference-design constant.
Connector Bottlenecks
The GaN power stage can be compact while phase-wire connectors and heavy copper still dictate board footprint.
Mitigation: Select connector families, phase-wire exits, and copper stack-up before claiming a target square-centimeter envelope.
24V Current Penalty
Keeping the bus at 24V raises current for the same mechanical power compared with 48V or 60V architectures.
Mitigation: Escalate to a higher bus voltage or reduce continuous duty when cable loss and PCBA heat dominate the trade-off.
Frequently Asked Questions
Why choose 24V for a GaN BLDC driver board?
Should I use Trapezoidal or FOC for a GaN BLDC board?
Can this board run sensorless BLDC motors?
What information is needed to quote a custom 24V BLDC driver?
When should a 24V BLDC project move to 48V?
Does GaN automatically make the driver board smaller?
Can the calculator output be used as a final specification?
What feedback type is best for zero-speed torque?
Is sensorless control acceptable for robotics?
What production checks matter most for this board?
Can GanServo build only the power stage?
Send the calculator result with motor constants, feedback choice, board envelope, cooling path, and target production volume so the first engineering reply can focus on feasibility instead of missing intake data.
For a separate 24 V PMSM operating-point screen, see the 24V GaN PMSM drive-board review.
For a DC bus-current estimate and sourced integration boundaries, see the 24V GaN servo amplifier board guide.